Seminar "Selected Topics in Machine Learning"
| Basic Information | |
|---|---|
| Lecturers: | Gerhard Schmidt and group |
| Semester: | Winter term |
| Language: | English or German |
| Target group: | Master students in electrical engineering and computer engineering |
| Prerequisites: | Fundamentals in digital signal processing |
| Registration procedure: |
If you want to sign up for this seminar, you need to register with the following information in the form
Please note that the registration period starts 05.10.2026 at 08:00 h and ends 23.10.2026 at 23:59 h. All applications before and after this registration period will not be taken into account. Registration will be possible within the before mentioned time by sending an e-mail with the desired seminar topic, name and matriculation number to Only one student per topic is permitted (first come - first serve). The registration is binding. A deregistration is only possible by sending an e-mail with your name and matriculation number to |
| Time: |
Preliminary meeting per arrangement with individual supervisor Written report due on 07.02.2027 Final presentations, 11.02.2027 (preliminary) |
| Contents: |
Students write a scientific report on a topic closely related to the current research of the DSS group.Therefore, potential topics include pattern recognition and machine learning related aspects. Students will also present their findings in front of the other participants and the DSS group. |
Topics for WS 26/27
| Topic title | Description |
|---|---|
| Machine Learning based 3D Beamforming for Underwater SONAR Systems |
Beamforming is a fundamental technique in sonar signal processing and is frequently used for spatial filtering and direction-of-arrival estimation. Conventional beamforming methods require an explicit acoustic model and scan a predefined spatial grid to estimate the position of sound sources or targets. However, in realistic underwater environments, noise, multipath propagation and array imperfections can significantly degrade the performance of these methods. Machine learning offers new possibilities for improving spatial estimation by learning complex relationships directly from acoustic data. The aim of this seminar is to investigate machine learning approaches for three-dimensional beamforming and the estimation of the direction of arrival in underwater sonar systems. Therefore, classical methods such as conventional beamformer will be compared with approaches based on neural networks, regarding spatial resolution, robustness and computational efficiency in three-dimensional sonar imaging. |
| Speech Evaluation Metrics |
The assessment of speech quality and intelligibility is of great interest, both in speech therapy and in the evaluation of algorithms for improving speech signals with regard to interference factors such as noise and reverberation. The aim of this seminar paper is to summarize and compare various objective assessment methods. In addition to traditional assessment criteria such as STOI, PESQ, etc., approaches based on neural networks should also be used for the comparison. |
| Machine Learning Based Spatial Filtering |
Direction-of-arrival (DoA) estimation is a fundamental task in signal processing. Classical approaches such as beamforming are widely applied, for example with microphone arrays or hydrophones in underwater acoustics. In addition to these established methods, new sensor technologies are gaining increasing relevance. Of particular interest are optical fibers, which, through Distributed Acoustic Sensing (DAS), can detect and localize acoustic signals along the fiber. The aim of this seminar paper is to explore how beamforming methods can be implemented and enhanced using Machine Learning. A special focus will be placed on identifying synergies between the concepts of Distributed Acoustic Sensing and Machine-Learning-based beamforming approaches. |
| AI-Driven Analysis of Passive Sonar Waterfall Plots: Automated Pattern Recognition and Decision Support |
Passive SONAR systems continuously generate waterfall plots that display acoustic signals over time and frequency. Traditionally, their interpretation has relied on the expertise of SONAR operators, who must identify patterns such as propeller frequencies, machinery noise, or biological signals. With the integration of Artificial Intelligence, new opportunities arise to automate signal detection and classification, increasing both efficiency and accuracy. In this seminar your goal is to gain an overview of current research trends and future scenarios. |
| Robust target tracking in multistatic SONAR with GMMs |
In a multistatic SONAR network, passive sonobuoys listen while an active source pings; targets are localized from time-difference-of-arrival (TDOA) measurements. In practice, harsh underwater conditions mean TDOA is often insufficient or noisy, so naïve geometric intersection quickly fails. Building on Shin et al., you will model a simplified 2D scenario (few receivers, limited SNR, missed/false detections) and study robust tracking when TDOA constraints are incomplete: compare baseline ellipse-/hyperbola-intersection and standard data association against likelihood-based track splitting and stack-based association, then explore how a small ML component (e.g., a classifier for association or a learned gating rule) can further stabilize tracks. Your goal is to propose and evaluate a pipeline that maintains accurate trajectories despite sparse, ambiguous TDOA. |
| Self-supervised Learning for Underwater Acoustic Channel Characterization |
Underwater acoustic communication and SONAR systems are strongly affected by time-varying channel conditions such as multipath propagation, reverberation, attenuation, and ambient noise. This seminar investigates how self-supervised learning can be used to characterize underwater acoustic channels directly from measured signals without relying on extensively labeled datasets. The focus is on evaluating whether learned representations capture relevant channel properties and can support subsequent underwater acoustic signal processing tasks. |
| Risk-Aware Path Planning for an Intruder under Uncertain Passive Sonar Geolocation |
Sonar systems detect underwater objects either passively, by listening for sound, or actively, by emitting a signal (a "ping") and analyzing its reflection or reception elsewhere. In a monitored area equipped with such active sender nodes, an intruder moving through the area can be exposed to detection each time a ping occurs, even though the exact sender positions are never directly revealed to it. From the pings it receives, the intruder can only estimate a noisy bearing and a known arrival level; combining several such measurements from different locations allows it to gradually and imprecisely triangulate sender positions, while its detection risk also depends on its own aspect relative to each sender. This setting combines elements of sequential state estimation, decision-making under uncertainty, and risk-aware planning, each with its own body of literature to draw on. Building on recent work combining reinforcement learning with bearings-only estimation, you will investigate how such a growing, uncertain belief about the threat environment can be incorporated into a machine learning agent's decision-making to support efficient, low-risk navigation from a start to a goal point. The focus is on comparing viable ML approaches to this sequential estimation-and-planning task rather than solving the problem optimally. |
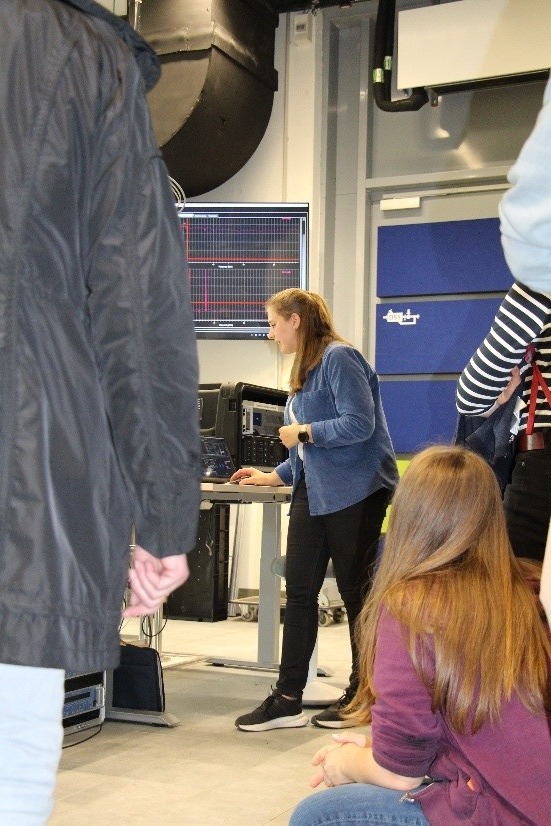 Science Day took place in Kiel and at the Faculty of Engineering on 25 September 2026. The DSS group contributed two demonstrations that gave visitors an insight into current research on signal processing, underwater acoustics and speech signals.